Human and robot experience becomes governed training data.
GappAI Labs / Research & Applied Robotics
Applied research for physical intelligence.
GappAI Labs is the research and applied robotics group of GappAI GmbH. It studies how human expertise becomes deployable robot intelligence across embodiments and real operating environments.
Research direction / Illustrative
Human expertise. Robot intelligence.
01 / Role in GappAI
Research layer
The research engine behind the deployment system.
GappAI Labs brings the company’s foundational and applied work into one research structure. It frames questions, structures controlled experiments and evaluates methods across human expertise, multimodal data, robot learning, simulation and real-world deployment.
Validated methods move into GappAI Capture, Skills and Workforce. Operational evidence returns new research questions to Labs.
Research layerGappAI Labs
Questions · experiments · methods · evaluation
Validated learning becomes versioned robot capability.
Capability operates within defined real-world boundaries.
Research continuum
Human expertise→Multimodal data→Robot learning→Reusable skills→Deployment→Operational learning
02 / Research Areas
Current directions
Problems that connect learning to physical work.
Each direction supports the same objective: reliable skills that can move from evidence to deployment without being defined by one robot manufacturer.
Human-to-Robot Skill Transfer
Methods for translating professional demonstrations and operating experience into robot behaviour.
Dexterous Manipulation & Multimodal Perception
Combining vision, depth, force, touch and task context for contact-rich physical work.
Cross-Embodiment Learning
Studying how a learned skill can be adapted and evaluated across different humanoid and robotic embodiments.
Adaptive Autonomy & Recovery
Reasoning under changing conditions, recovering from failure and requesting human intervention when required.
Simulation, Evaluation & Safety
Testing skills against measurable performance and safety criteria before and throughout field deployment.
Multimodal perception / Illustrative
See the task. Understand the contact.
03 / Research Projects
Evidence before claims
Projects enter the record when the work can be shown.
GappAI Labs will publish projects with a defined question, method, status and evidence. No completed research project is presented publicly at this stage.
First skill family / Development focusIndustrial Kitting
Industrial Kitting
& Machine Tending
A bounded, repeatable starting point: prepare industrial part kits and load or unload a machine, with measurable part quality, cycle time and intervention frequency.
Berlin GappAI Labs → test cell → customer pilot
- 01 / Define the test cell
One operation, specified parts, tools and acceptance criteria. Confirm robot access and sensing before experiments begin.
- 02 / Capture the work
Translate expert demonstrations and relevant contact, motion and sensor data into the Work Graph.
- 03 / Learn & simulate
Develop a skill candidate and adapter. Evaluate variations, failures and recovery in simulation.
- 04 / Validate physically
Run repeated robot tests with documented volume, conditions, successes, failures and human interventions.
- 05 / Release the evidence
Review the Skill Passport. A paid customer pilot follows only with suitable evidence and agreed operating boundaries.
Planned validation pathway; this does not claim completed tests or acquired robots. A research platform — including an AgiBot if selected — develops GappAI’s technology; it is not the product itself.
Skill family architecture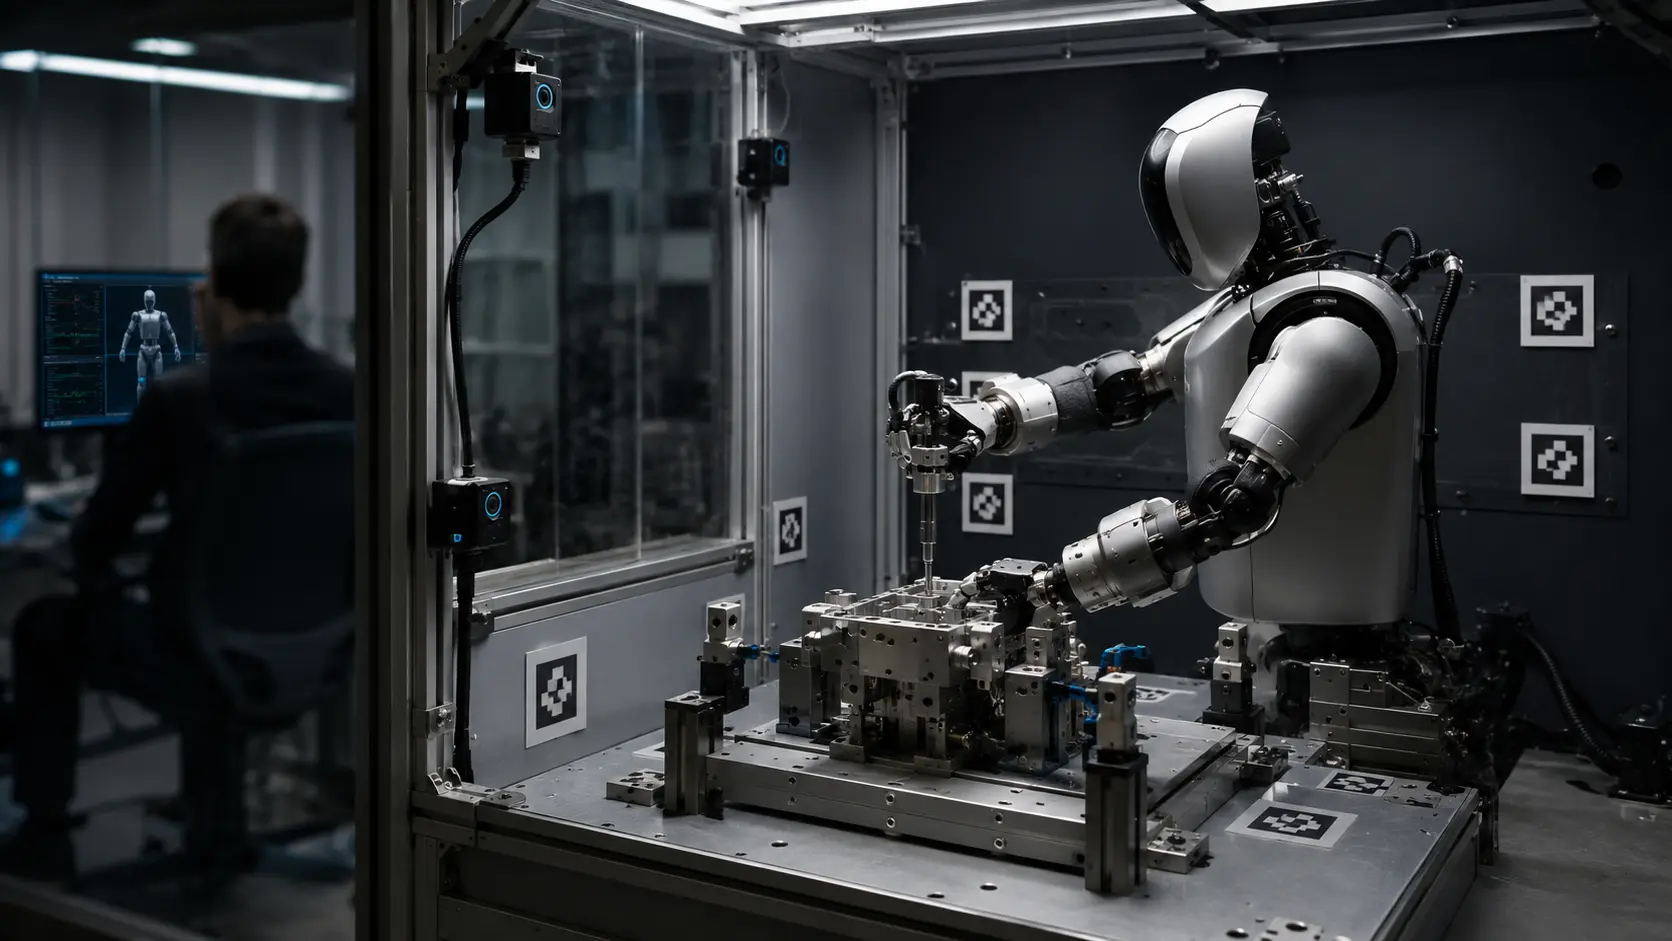
Evaluation & safety / Illustrative
Measure before deployment.
04 / Technical Notes
Published work
Technical work, documented.
GappAI Labs Technical Notes document engineering frameworks, research questions and evaluation approaches. They are not marketing articles or company announcements.
Latest / Technical Note 01
View all Technical Notes From human demonstration to reliable robot skill
14 August 2026 · 8 min read
An engineering framework for capturing expert work, learning multimodal policies and building a controlled path from demonstration to deployment.
05 / Research Platforms
Verified infrastructure
Infrastructure enters the record when it enters active use.
The research platform register is designed to document verified humanoid platforms, sensors, teleoperation systems, simulation environments and compute systems used in GappAI Labs work.
Research platform registerNo public entries yet
A platform will be listed only after it is available to GappAI Labs for active research. No ownership, partnership or deployment is implied before verification.
Register scope
Humanoid systems · Instrumented capture · Teleoperation · Simulation · Compute & evaluation
06 / Academic Partnerships
Research collaboration
Scientific questions. Real systems.
GappAI Labs provides the research context for focused collaboration with universities, laboratories, researchers and students—across joint research, thesis work, academic validation and responsible robotics.
Explore Academic PartnershipsResearch & applied robotics